
EPISODE · Aug 26, 2025 · 8 MIN
【第330期】(中文)UniVLA: 通用机器人策略学习框架
from Seventy3
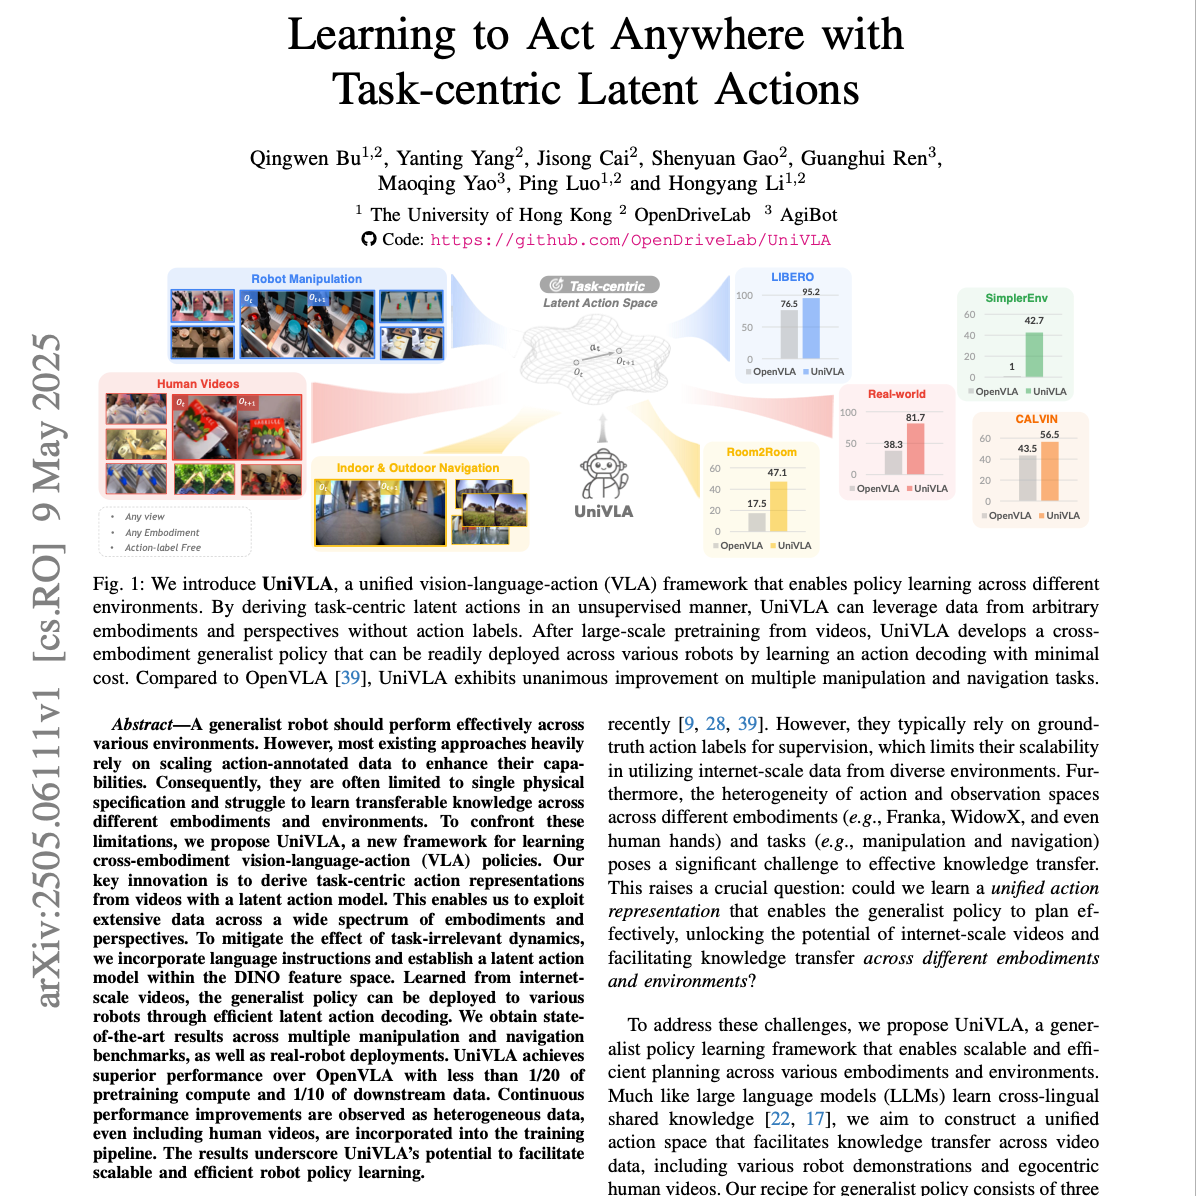
Seventy3:借助NotebookLM的能力进行论文解读,专注人工智能、大模型、机器人算法方向,让大家跟着AI一起进步。今天的主题是:Learning to Act Anywhere with Task-centric Latent ActionsSummary这篇研究介绍了 UniVLA,一个用于机器人学习的统一 视觉-语言-动作 (VLA) 框架。该框架的核心创新在于以无监督的方式从视频中学习以任务为中心的潜在动作,使其能够利用来自不同机器人和视角的大量数据,而无需动作标签。通过在大规模视频数据上进行预训练,UniVLA 能够开发出一种跨机器人通用策略,只需最低成本的动作解码即可轻松部署到各种机器人上。研究强调,UniVLA 在多种操纵和导航任务中表现出色,显著优于现有方法,同时需要的计算资源和下游数据也更少,展示了其在可扩展和高效机器人策略学习方面的巨大潜力。原文链接:https://arxiv.org/abs/2505.06111前往小宇宙评论区与主播互动
Embed this episode
Ready to play
【第330期】(中文)UniVLA: 通用机器人策略学习框架
0:00
8:10
1×
No transcript for this episode yet
Similar Episodes
No similar episodes found.
Similar Podcasts
No similar podcasts found.
Frequently Asked Questions
How long is this episode of Seventy3?
This episode is 8 minutes long.
When was this Seventy3 episode published?
This episode was published on August 26, 2025.
Can I download this Seventy3 episode?
Yes. Use the download control on the episode player to save the publisher-provided media file.
URL copied to clipboard!