Ep#45: HERMES: Human-to-Robot Embodied Learning From Multi-Source Motion Data for Mobile Dexterous Manipulation
from RoboPapers Hosted by Chris Paxton
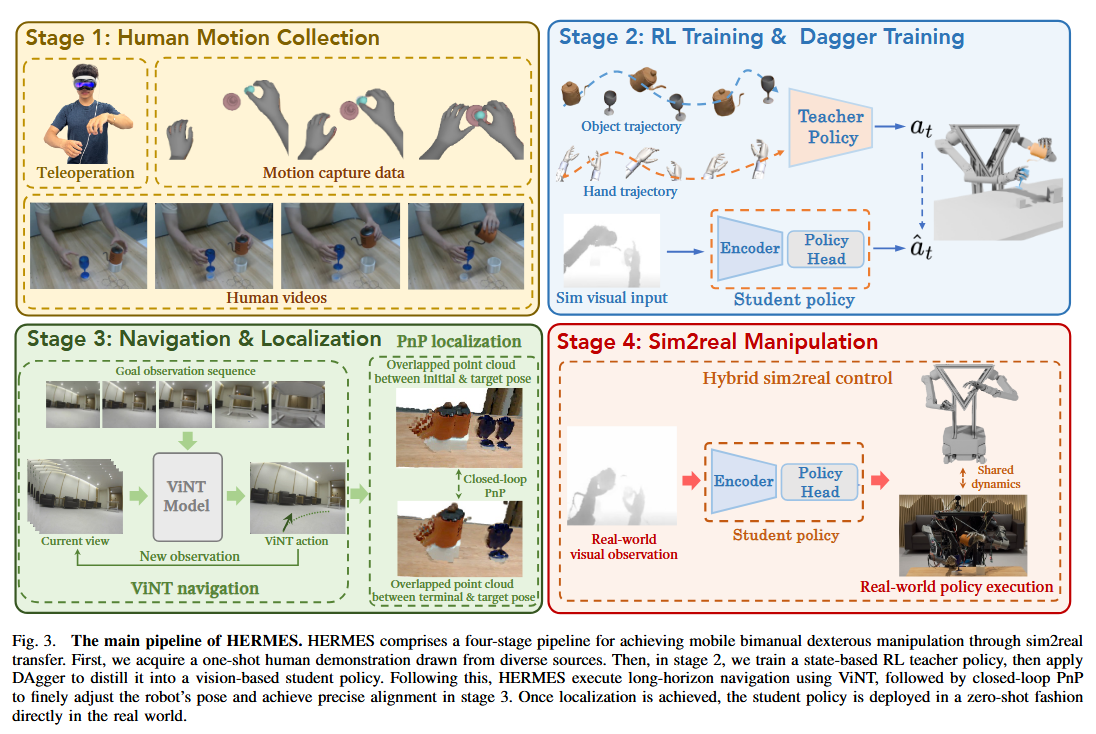
Just collecting manipulation data isn’t enough for robots - they need to be able to move around in the world, which has a whole different set of challenges from pure manipulation. And bringing navigation and manipulation together in a single framework is even more challenging. Enter HERMES, from Zhecheng Yuan and Tianming Wei. This is a four-stage process in which human videos are used to set up an RL sim-to-real training pipeline in order to overcome differences between robot and human kinematics, and used together with a navigation foundation model to move around in a variety of environments. To learn more, join us as Zhecheng Yuan and Tianming Wei tell us about how they built their system to perform mobile dexterous manipulation from human videos in a variety of environments. Watch Episode #45 of RoboPapers today, hosted by Michael Cho and Chris Paxton! Abstract: Leveraging human motion data to impart robots with versatile manipulation skills has emerged as a promising paradigm in robotic manipulation. Nevertheless, translating multi-source human hand motions into feasible robot behaviors remains challenging, particularly for robots equipped with multi-fingered dexterous hands characterized by complex, high-dimensional action spaces. Moreover, existing approaches often struggle to produce policies capable of adapting to diverse environmental conditions. In this paper, we introduce HERMES, a human-to-robot learning framework for mobile bimanual dexterous manipulation. First, HERMES formulates a unified reinforcement learning approach capable of seamlessly transforming heterogeneous human hand motions from multiple sources into physically plausible robotic behaviors. Subsequently, to mitigate the sim2real gap, we devise an end-to-end, depth image-based sim2real transfer method for improved generalization to real-world scenarios. Furthermore, to enable autonomous operation in varied and unstructured environments, we augment the navigation foundation model with a closed-loop Perspective-n-Point (PnP) localization mechanism, ensuring precise alignment of visual goals and effectively bridging autonomous navigation and dexterous manipulation. Extensive experimental results demonstrate that HERMES consistently exhibits generalizable behaviors across diverse, in-the-wild scenarios, successfully performing numerous complex mobile bimanual dexterous manipulation tasks Project Page: https://gemcollector.github.io/HERMES/ ArXiV: https://arxiv.org/abs/2508.20085 This is a public episode. If you would like to discuss this with other subscribers or get access to bonus episodes, visit robopapers.substack.com
Embed this episode
No transcript yet.