Ep#7: AnyDexGrasp: General Dexterous Grasping for Different Hands with Human-level Learning Efficiency
from RoboPapers Hosted by Chris Paxton
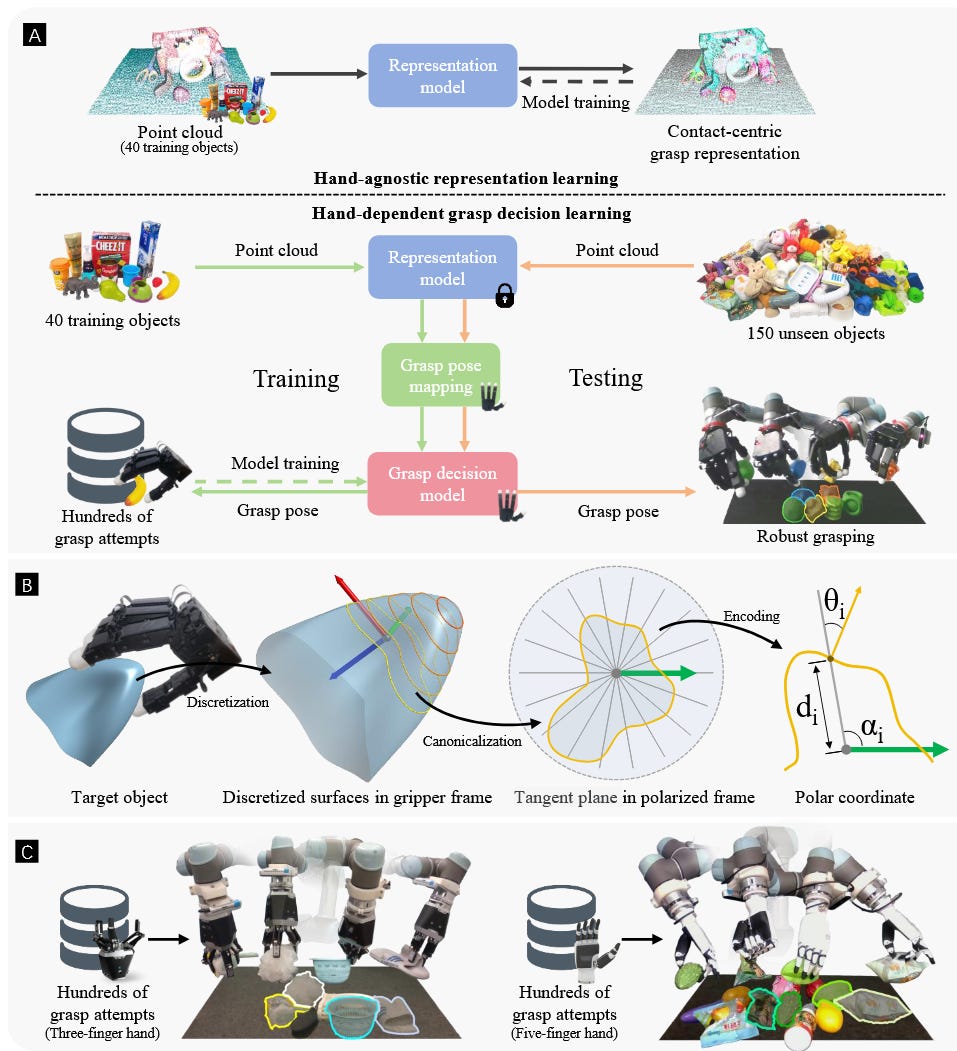
Hao-Shu talks to us about how we can learn a contact-centric grasp representation which works across many different robots. We introduce an efficient approach for learning dexterous grasping with minimal data, advancing robotic manipulation capabilities across different robotic hands. Unlike traditional methods that require millions of grasp labels for each robotic hand, our method achieves high performance with human-level learning efficiency: only hundreds of grasp attempts on 40 training objects. The approach separates the grasping process into two stages: first, a universal model maps scene geometry to intermediate contact-centric grasp representations, independent of specific robotic hands. Next, a unique grasp decision model is trained for each robotic hand through real-world trial and error, translating these representations into final grasp poses. Our results show a grasp success rate of 75-95% across three different robotic hands in real-world cluttered environments with over 150 novel objects, improving to 80-98% with increased training objects. This adaptable method demonstrates promising applications for humanoid robots, prosthetics, and other domains requiring robust, versatile robotic manipulation. Paper on ArXiV This is a public episode. If you would like to discuss this with other subscribers or get access to bonus episodes, visit robopapers.substack.com
Embed this episode
No transcript yet.